Mobile Robotics Gallery
Showcase of cutting-edge mobile robotics systems and demonstrations
🌱 Agricultural Robotics
TerraMax - Autonomous Agricultural Robot
Source: EarthSense | Website: TerraMax Product Page
TerraMax represents the cutting edge of autonomous agricultural robotics, designed to revolutionize precision farming through advanced sensor fusion and autonomous navigation capabilities. This system demonstrates real-world applications of mobile robotics concepts covered in CS498GC.
Key Technologies Demonstrated:
- Autonomous Navigation: GPS-based path planning and obstacle avoidance
- Sensor Fusion: Multi-modal sensor integration for crop monitoring
- Computer Vision: Plant detection and health assessment
- Precision Agriculture: Targeted intervention and data collection
- Robotic Mobility: All-terrain autonomous operation
Course Relevance:
- Modules 1-2: Coordinate transformations in agricultural mapping
- Module 4: Sensor fusion for crop monitoring
- Module 6: Localization in outdoor environments
- Module 7: SLAM applications in precision agriculture
The TerraMax demo video that was embedded here in Fall 2025 is no longer available on YouTube.
📚 Learn More
Company: EarthSense
Technology: Autonomous Agricultural Robotics
Application: Precision Farming & Crop Monitoring
🌿 Greenhouse Robotics & Precision Agriculture
Mobile Manipulator for Active Semantic Mapping
Paper: J. Cuaran, K. S. Ahluwalia, K. Koe, N. K. Uppalapati, G. Chowdhary, Active Semantic Mapping with Mobile Manipulator in Horticultural Environments, ICRA 2025 (arXiv 2412.10515)
A mobile robot manipulator with an RGB-D camera builds probabilistic semantic maps of horticultural crops and chooses where to look next: it detects semantic targets, generates candidate viewpoints and scores them by information gain. The paper reports real-world experiments, which also show challenges such as depth sensor noise and changing environmental conditions.
Key Technologies Demonstrated:
- Mobile Manipulation: a mobile robot manipulator with an RGB-D camera
- Active Semantic Mapping: semantic mapping of horticultural crops with a mobile manipulator (Cuaran, Ahluwalia, Koe, Uppalapati, Chowdhary, ICRA 2025)
- Viewpoint Planning: candidate viewpoints scored with an information utility that accounts for semantics and occlusions
- Efficient Ray Casting: for computing the information gain of each viewpoint
Course Relevance:
- Assignment 4: Mobile manipulator setup and control
- Module 7: SLAM for greenhouse navigation
- Module 8: Semantic mapping and scene understanding
- Extra Credit: Advanced perception with SAM & RTAB-Map
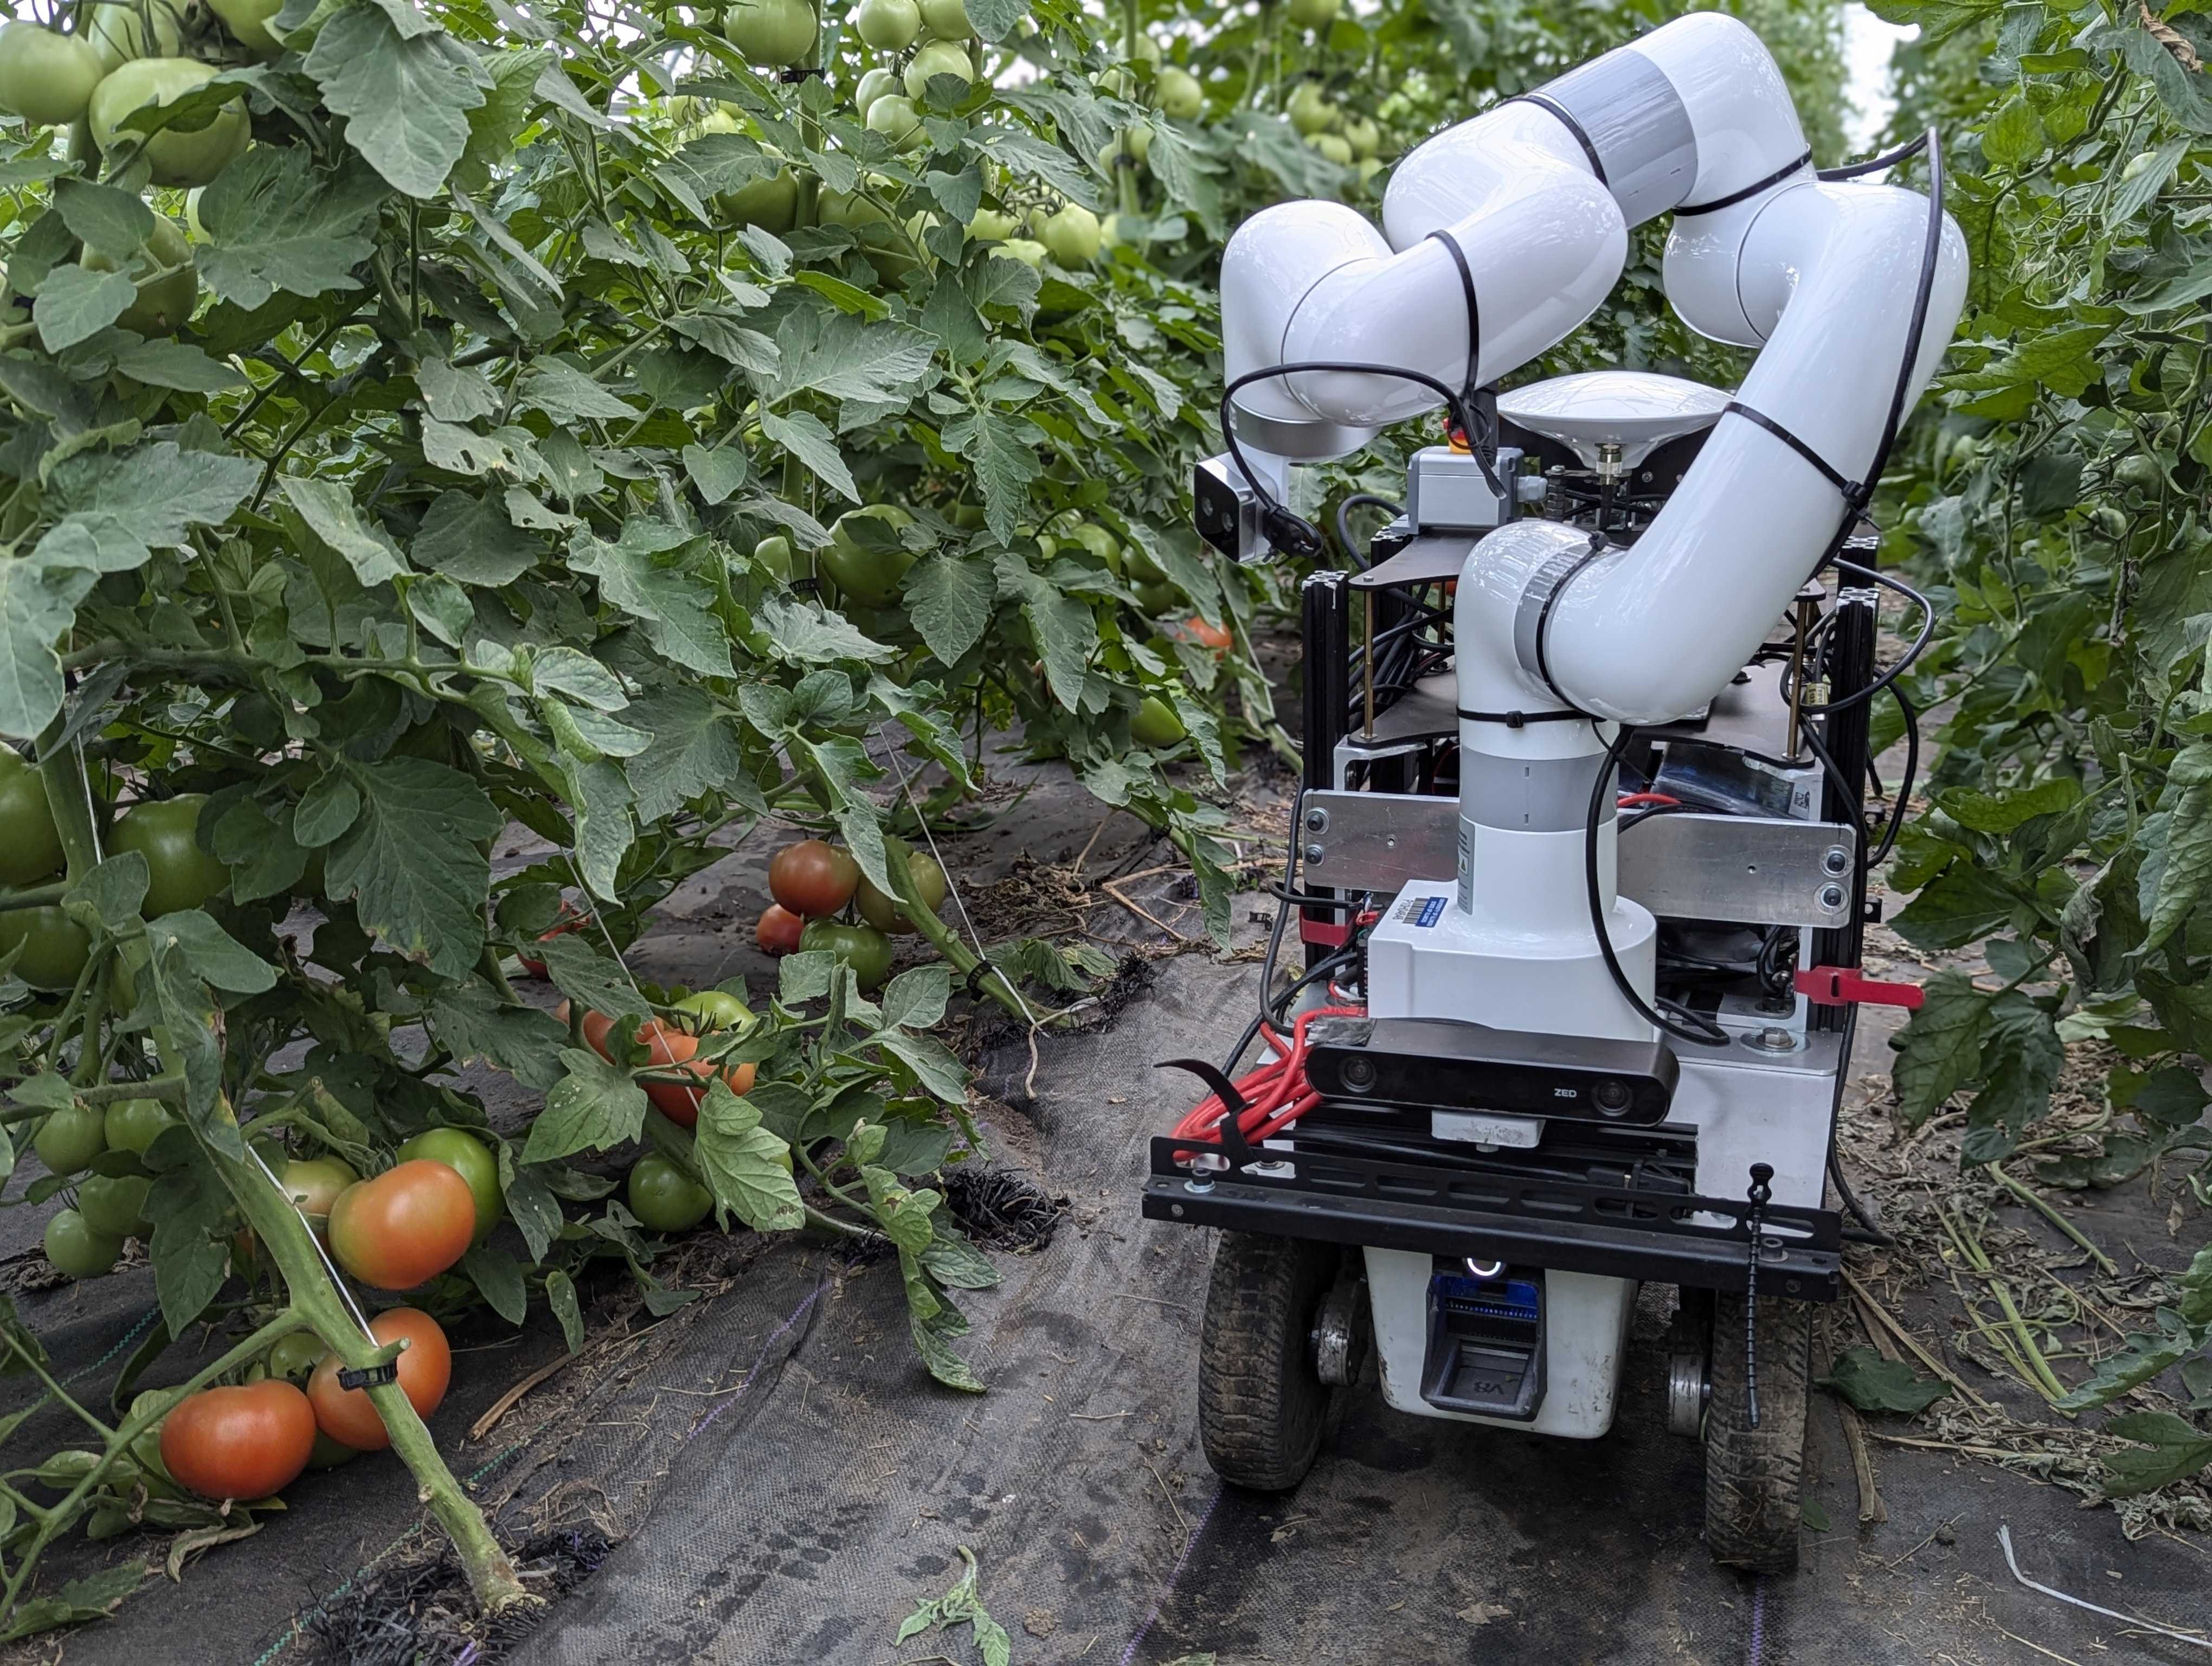
🤖 System Summary
Platform: mobile robot manipulator
Sensor: RGB-D camera
Application: Active semantic mapping in horticultural environments
Assignment 4 TA Reference Runs
TA reference runs, not student submissions
Recorded TA runs of the course's Husky + UR3 mobile manipulator in Gazebo Harmonic (ROS 2 Jazzy, NVIDIA DGX Spark, July 2026): the Part 1 setup with a scripted base drive, and the Part 2 SLAM-on-Mars run (scripted drive, EKF sensor fusion and SLAM Toolbox), ending with a saved occupancy map. October 2026 re-runs on an MSI x86 laptop (Part 2: 15 of 15 waypoints reached, ground-truth error mean 0.256 m, max 0.395 m) and an RTAB-Map extra-credit run on the DGX Spark (trajectory error 0.271 m RMSE vs 0.725 m for wheel odometry) are on the SLAM-ing Mars page.
Watch the TA reference runs →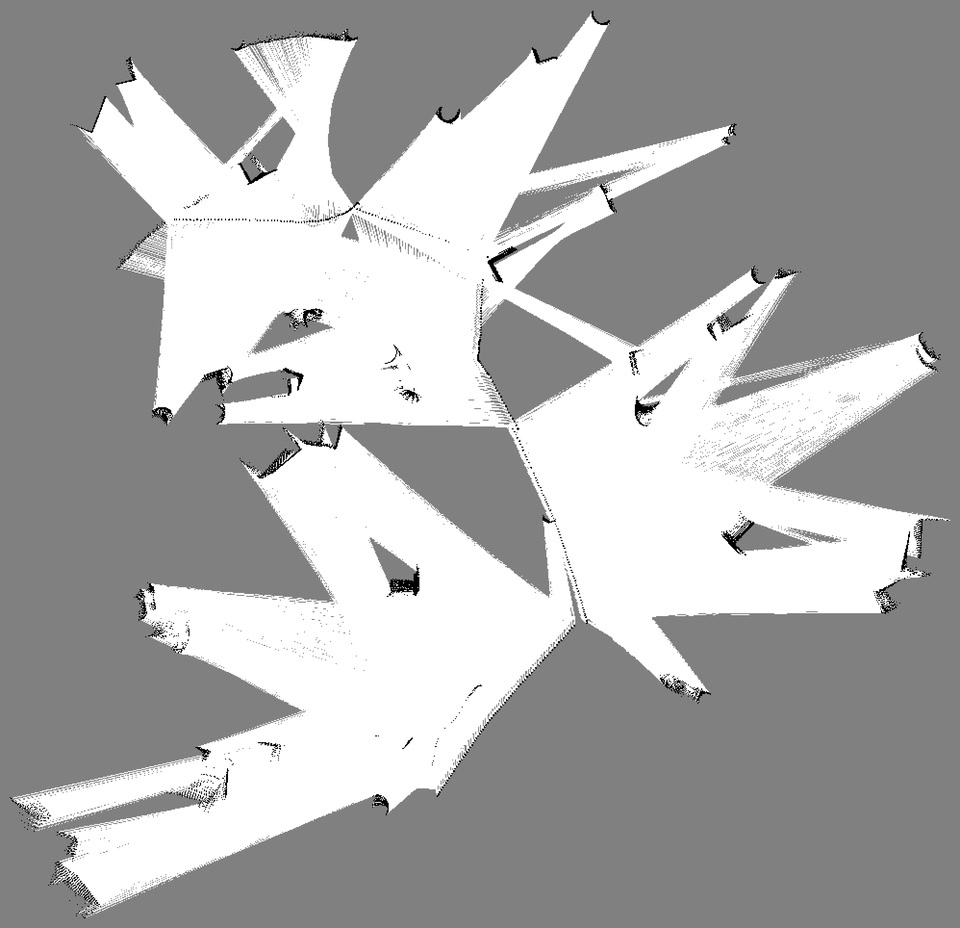
Final SLAM Toolbox occupancy map from the Part 2 TA reference run.
🎯 Educational Purpose
This gallery showcases real-world applications of mobile robotics technologies to help students understand the practical implementation of concepts learned in CS498GC. All content is used for educational purposes with proper attribution to the original creators.
📝 Attribution & Citations
All videos and content in this gallery are the property of their respective owners and are used here for educational purposes only. Please visit the original sources to learn more about these innovative robotics companies and their products.